
COURSES & TUTORIALS
This course is an introduction to the basic concepts of artificial intelligence (AI) as is practiced in the 2020s. At the end of this course you will be able to build AI systems that you can train to solve a variety of problems.
Graph Neural Networks (GNNs) are information processing architectures for signals supported on graphs. They have been developed and are presented in this course as generalizations of the convolutional neural networks (CNNs) that are used to process signals in time and space.
This course covers the fundamentals of deep learning and the basics of deep neural networks, including different network architectures and optimization algorithms for training these networks, as well as applications to computer vision, robotics, and sequence modeling.
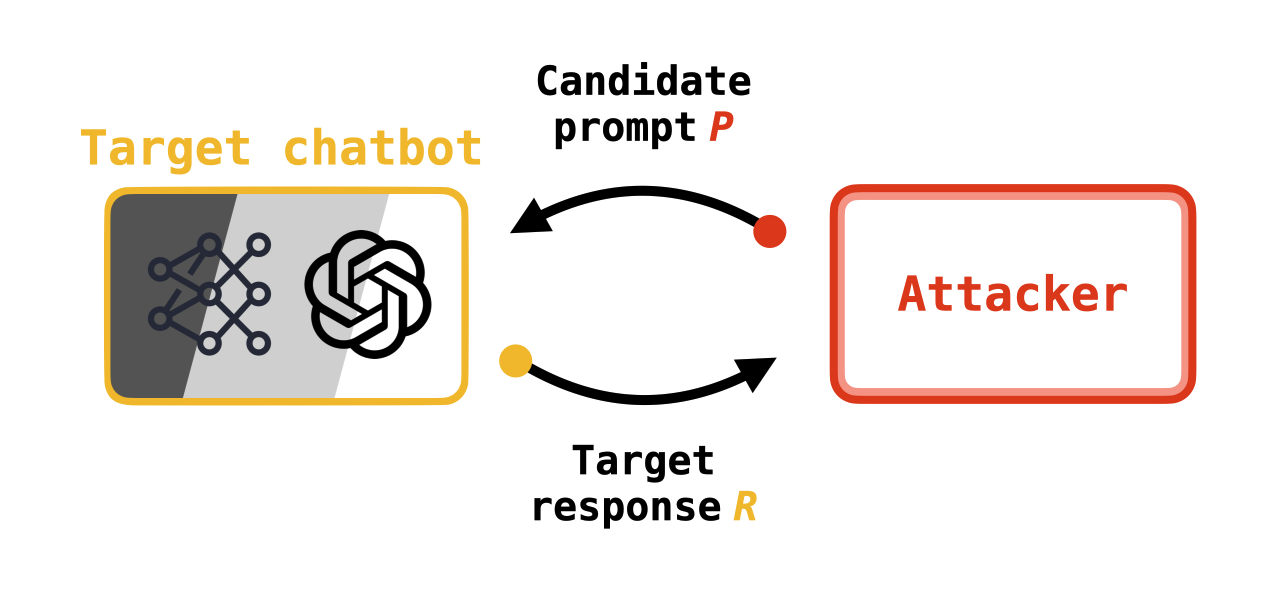
This tutorial provides an overview of recent advances in jailbreaking attacks, defenses, and evaluation methods, with particular emphasis on applications in robotics and agentic systems.
This undergraduate-level course focuses on single-input single-output linear time-invariant control systems emphasizing frequency-domain methods. Topics include modeling of feedback control systems, transient and steady-state behavior, Laplace transforms, stability, root locus, frequency response, Bode plots, Nyquist plots, Nichols plots, PID control, and loop shaping.
This course covers optimal control fundamentals and their application to motion planning and decision making in robotics. Topics include Markov decision processes (MDPs), dynamic programming, search-based and sampling-based motion planning, value and policy iteration, linear quadratic regulation (LQR), and model-free reinforcement learning.
An introduction to robotics algorithms for mapping, localization, planning, and control, as well as a realistic testbed to try before deploying the algorithms on a real robot. The PyBullet physics simulator is used to demonstrate these algorithms on ground wheeled robots in simulation.
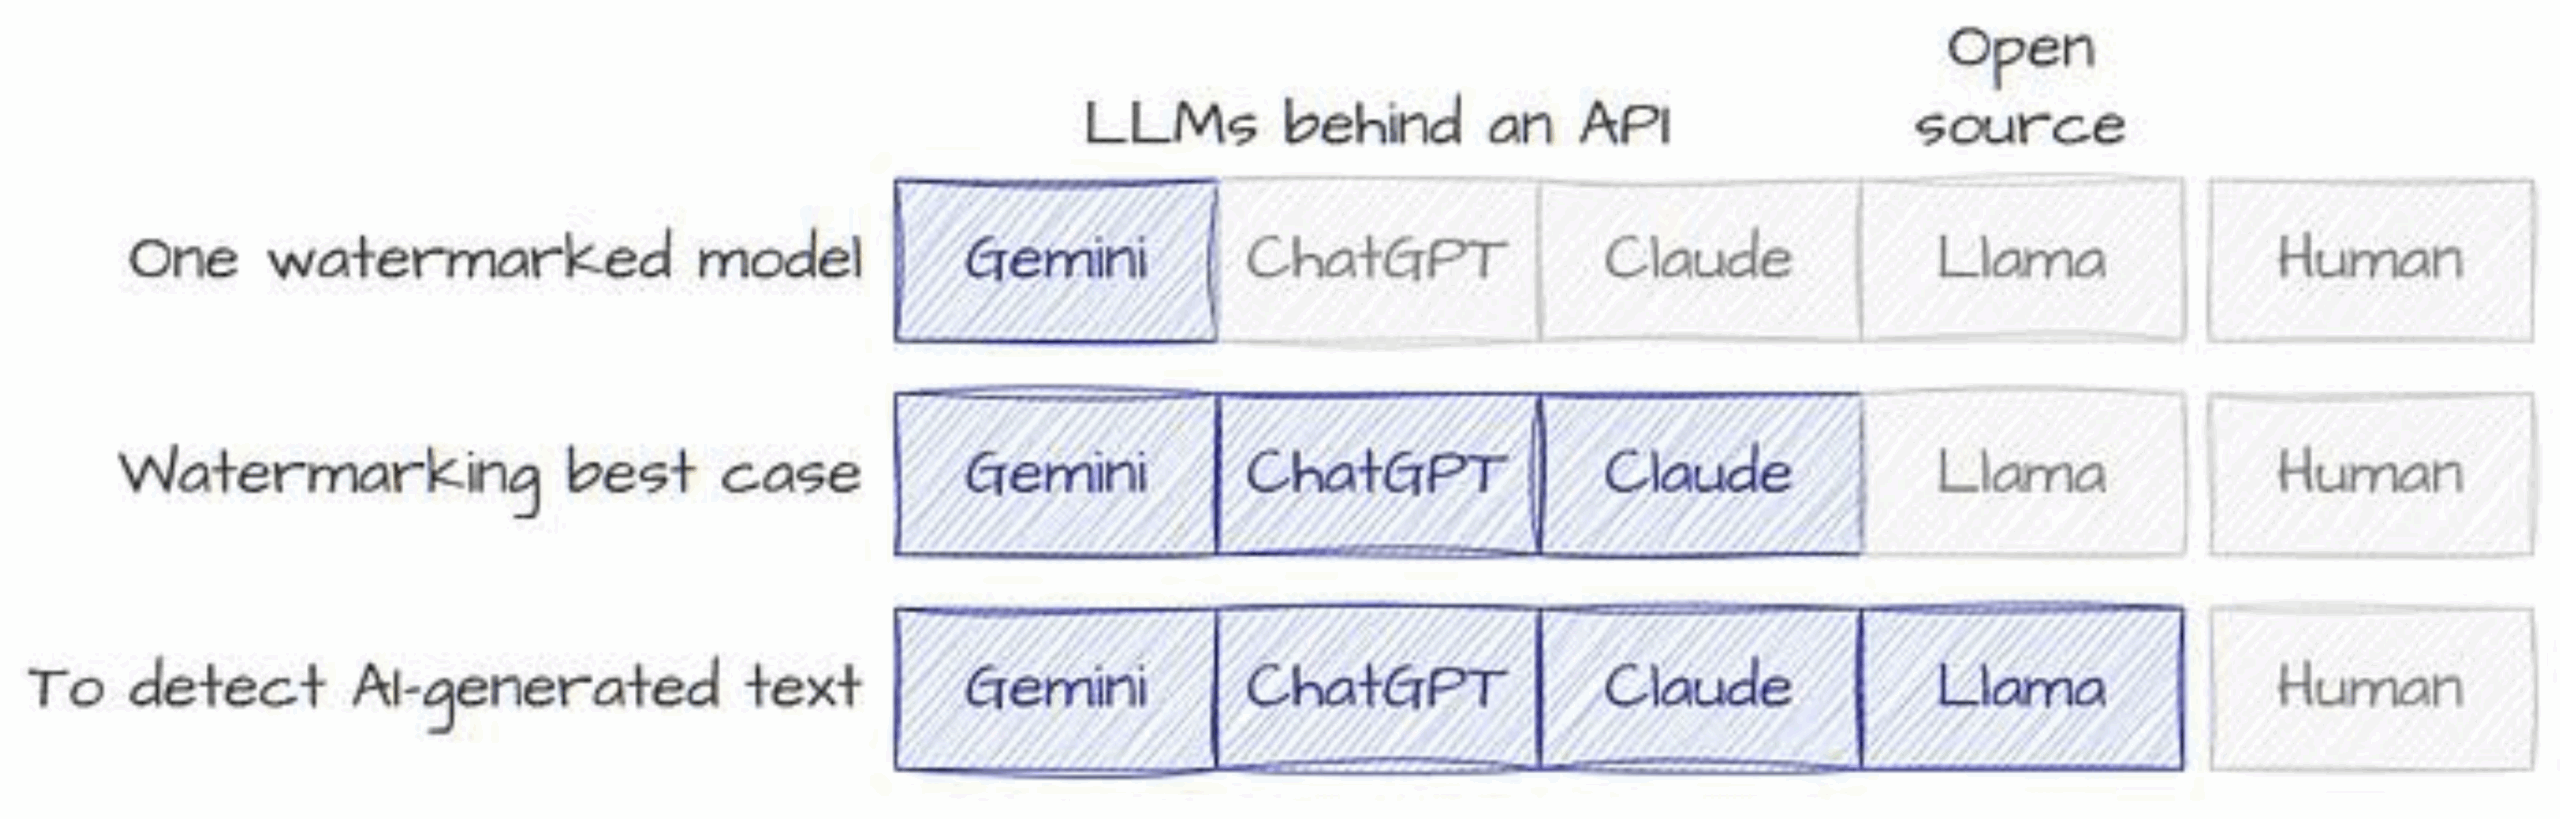
The rapid advancement of generative AI has brought remarkable innovations, from creating realistic images to generating human-like text. However, this power comes with significant responsibility. AI safety is crucial to ensure these systems are used ethically, fairly, and without unintended harm. Without proper safety measures, generative AI can spread misinformation, reinforce biases, or be exploited for malicious purposes. By prioritizing AI safety, researchers and developers can build trust, create guidelines for responsible use, and mitigate risks before they affect society on a large scale.
More coming soon...
SOFTWARE & DATASETS
TILOS researchers share open-source software, datasets, benchmarks and contests so others can build on our work. Each card shows the year the project was first released, newest first within each category.
Chip Design & EDA
Open tools, benchmarks and contests for AI-driven chip design.
-
Released 2026Contest
ICCAD 2026 Contest: FloorSet Challenge
Data-driven system-on-chip floorplanning contest.
-
Released 2025
Process-Voltage-Temperature and Pareto-Aware Analog Sizing (PPAAS)
Goal-conditioned reinforcement learning for analog circuit sizing that holds up across process, voltage and temperature.
-
Released 2024
Directed Equivariant Hypergraph Neural Network (DE-HNN)
Directed hypergraph model that predicts post-routing congestion from netlists, plus a large netlist benchmark.
-
Released 2024
Clustering-Driven Chip Placement (BlobPlace)
Clustering-driven placement for large VLSI designs, tuned for power, performance and area.
-
Released 2023
TritonPart
Hypergraph partitioner (v2 adds timing-driven partitioning) integrated into the OpenROAD RTL-to-GDS flow.
-
Released 2023Contest
MLCAD 2023 Contest: Field-Programmable Gate Array (FPGA) Macro Placement
ML contest organized by AMD with UCSD students: 150+ new benchmarks, 18 teams worldwide.
-
Released 2023Contest
Multi-Source Prim-Dijkstra Contest
Routing-tree contest run by a high-school student mentored in the Kahng lab; 22 teams worldwide.
-
Released 2022
MacroPlacement
Open, transparent baseline of Google's deep-RL chip macro placement, with benchmarks and evaluators.
-
Released 2022
Hypergraph Partitioning for Very-Large-Scale Integration (VLSI)
Benchmarks, code and leaderboard, including the SpecPart and K-SpecPart solution-improvement frameworks.
Includes: SpecPart, K-SpecPart
-
Released 2021
Analytical Placement for Field-Programmable Gate Arrays (DREAMPlaceFPGA)
GPU-accelerated analytical placer for large heterogeneous FPGAs, now timing-driven; FCCM 2024 Best Paper.
Robot Planning, Control & Safety
Safe planning, control and coordination for robots and robot teams.
-
Released 2026
Graph-based Adversarial Multiagent Modelling Simulator (GAMMS)
Lightweight Python simulator for large-scale multi-agent scenarios on graph-structured environments.
-
Released 2025
RoboGuard
Two-stage safety guardrails that keep LLM-enabled robots from carrying out unsafe plans.
-
Released 2025
Heterogeneous Robot Teams with Grounded Generative Intelligence (SPINE-HT)
LLM-grounded planning that generates, assigns and refines tasks for heterogeneous robot teams.
-
Released 2025
Distilling On-Device Language Models for Robot Planning (PRISM)
Distills small on-device language models from LLM robot planners with minimal human input.
-
Released 2024
Distributionally Robust Safe Navigation
Safety filter that uses noisy sensor data directly to keep robots safe in dynamic, unknown environments.
-
Released 2024
Distributionally Robust Stable Policies
Learns control policies with Lyapunov stability guarantees under uncertainty.
-
Released 2023
Distributionally Robust Lyapunov Functions
Finds Lyapunov functions that certify stability under uncertainty.
-
Released 2023
Port-Hamiltonian Neural Ordinary Differential Equations on Lie Groups
Physics-structured networks for learning and controlling robot dynamics.
-
Released 2022
Lie Group Forced Variational Integrator Networks (LieFVIN)
Lie-group forced variational integrator networks for learning and controlling robot dynamics.
-
Released 2021
Hamiltonian Dynamics Learning on the SE(3) Manifold (SE3HamDL)
Hamiltonian neural ODEs on SE(3) for robot dynamics learning and control.
-
Released 2021
Multi-Robot Opportunistic Communication for Heterogeneous Collaboration (MOCHA)
Opportunistic communication for heterogeneous multi-robot collaboration.
Aerial Robotics
Flight software, planners and benchmarks for quadrotors.
-
Released 2025Benchmark
Reinforcement Learning vs. Geometric Control for Quadrotors
Benchmark and open implementations for fairly comparing learned and classical quadrotor controllers.
-
Released 2025
Learning-Based Time-Optimal Quadrotor Trajectory Planning (lbTOPPQuad)
LSTM planner that imitates a time-optimal planner to generate quadrotor trajectories faster.
-
Released 2025
Quadrotor Layered Control Decomposition (Quad-LCD)
Layered control decomposition for actuator-feasible quadrotor trajectory planning.
-
Released 2024
Optimal Convex Cover
Approximates collision-free space as convex polytopes along a path for safe trajectory planning.
-
Released 2023
Lightweight Learning-Based Trajectory Optimization (AllocNet)
Lightweight learning-based trajectory optimization.
-
Released 2023
Quadrotor Motion Planner Design
Guide and tools for designing and evaluating quadrotor motion planners.
-
Released 2023
Air Router
Replaces PX4 waypoint mission following for a high-altitude robot.
-
Released 2020
Kumar Robotics Autonomous Flight System (KR Autonomous Flight)
KumarLab's full autonomy stack for quadrotors in GPS-denied environments.
Robot Learning & Manipulation
Learning skills for manipulation, locomotion and humanoids.
-
Released 2025
Symbol and Skill Co-Invention (SymSkill)
Learns symbols and manipulation skills together from unlabeled play data for long-horizon tasks.
-
Released 2025
Embodiment Scaling Laws
Study of ~1,000 generated robot bodies showing that more diverse training improves locomotion on new robots.
-
Released 2025
Soft Gripper Co-Design
Jointly optimizes soft-gripper stiffness and grasp poses using a neural physics model.
-
Released 2025
Humanoid Policy ~ Human Policy
Co-trains humanoid and human behavior with an egocentric human dataset (PH2D) for better manipulation.
-
Released 2022
Multi-Skill Mobile Manipulation (M3)
Multi-skill mobile manipulation for long-horizon object rearrangement in the Habitat benchmark.
-
Released 2022
ManiSkill
Unified framework for robot simulation and training.
-
Released 2021
Dexterous Manipulation from Human Videos (DexMV)
Imitation learning of dexterous multi-finger manipulation from human videos.
Mapping, Perception & Autonomous Driving
Mapping, SLAM and perception for robots and self-driving cars.
-
Released 2025
Scalable Map Priors for Driving Topology Reasoning (SMART)
Map priors learned from standard and satellite maps for lane and road-topology reasoning in self-driving.
-
Released 2025
3D Spatial Multimodal Memory (M3)
Gaussian-splatting memory that stores vision-language features in 3D scenes; shown on a quadruped robot.
-
Released 2025
Gaussian Splatting for Online High-Definition Mapping (MapGS)
Novel-view synthesis that adapts camera data across sensor setups to improve online HD mapping.
-
Released 2024
Riemannian Optimization for Active Mapping (ROAM)
Riemannian optimization for active mapping with robot teams.
-
Released 2024
Sparse, Lightweight, Decentralized Simultaneous Localization and Mapping (SlideSLAM)
Sparse, lightweight, decentralized semantic SLAM for multi-robot navigation.
-
Released 2024
Semantic Vector Map Generation Network (SemVecNet)
Vector map generation that generalizes to any sensor configuration.
-
Released 2023
Convolutional Object Retrieval and Symmetry-Aided Registration (CORSAIR)
Convolutional object retrieval and symmetry-aided registration.
-
Released 2023Dataset
Treescope
Agricultural robotics dataset for lidar mapping of trees in forests and orchards.
-
Released 2022
Semantic Lidar Odometry and Mapping (SLOAM)
Semantic lidar odometry and mapping for forests.
-
Released 2022
Semantic Shannon Mutual Information (SSMI)
Active multi-class mapping using semantic Shannon mutual information.
-
Dataset
Autonomous Vehicle Laboratory Datasets
13+ hours of UCSD campus driving: NominalScenes, IntersectionScenes, AV Breadcrumbs (900K+ frames) and StopSigns.
Language Models & AI Agents
Training, evaluating and steering large language models and agents.
-
Released 2026Benchmark
Controller Area Network Question Answering (CAN-QA)
Question-answering benchmark for LLM reasoning over in-vehicle CAN bus traffic.
-
Released 2026Benchmark
Personal Health Assistant Benchmark (LifeAgentBench)
Large QA benchmark and baseline agent for long-horizon personal health reasoning.
-
Released 2025
Turn-level Information-Potential Reward Shaping (TIPS)
Turn-level reward shaping for training search-augmented LLMs with multi-turn reinforcement learning.
-
Released 2025
Teaching Large Language Models to Reason on Graphs (G1)
LLMs trained with reinforcement learning to reason about graphs while keeping general skills.
-
Released 2025
Aggregate and Conquer: Steering Concepts in Large Language Models
Toolkit to detect and steer concepts like honesty or harmfulness inside LLM activations.
-
Released 2024Benchmark
Persona Memory Benchmark (PersonaMem)
Benchmark for how well LLMs track changing user personas and personalize multi-session responses.
-
Released 2024Survey
Rationality in Language & Multimodal Agents
Survey defining rationality for AI agents and reviewing progress toward more rational decisions.
-
Released 2023
Layer Dropping for Domain-Specific Large Language Models (TrimLLM)
Progressive layer dropping to make domain-specific language models smaller and faster.
-
Released 2020
Language Model Evaluation Harness
EleutherAI's widely used open framework for evaluating language models; TILOS researchers contribute to the project.
Computer Vision & Generative AI
Image, video and multimodal generation and understanding.
-
Released 2025
ControlText
Diffusion method for font-controllable multilingual text in images, without font labels.
-
Released 2025
Unpaired Multimodal Learning
Uses unpaired image, text and audio data to train stronger single-modality models.
-
Released 2025
Compositional Generation with Lift Scores (CompLift)
Training-free check that helps diffusion models follow multi-part (compositional) prompts.
-
Released 2025
One-Minute Video Generation
Test-time-training layers let a diffusion transformer generate coherent minute-long videos from storyboards.
-
Released 2023
Open-Vocabulary Diffusion-Based Panoptic Segmentation (ODISE)
Open-vocabulary panoptic segmentation using text-to-image diffusion models.
-
Released 2022
Commonsense Scene Graphs
Scene-graph generation that adds hierarchical relationships and commonsense knowledge.
-
Released 2022
Transformers as Meta-Learners for Implicit Neural Representations (Trans-INR)
Transformers that directly generate the weights of implicit neural representations.
-
Released 2022
Grouping Vision Transformer (GroupViT)
Semantic segmentation that emerges from vision transformers trained only with text.
Machine Learning Foundations
Faster, more robust and better-understood machine learning.
-
Released 2026
Sparse Feature Attention (SFA)
Feature-sparse self-attention plus a fast CUDA kernel (FlashSFA) for long-context training.
-
Released 2024Benchmark
Out-of-Distribution Robustness Benchmark (OODRobustBench)
Benchmark and leaderboard of adversarial robustness for hundreds of models under distribution shift.
-
Released 2024
Grokking with Recursive Feature Machines (RFM)
Grokking modular arithmetic with recursive feature machines.
-
Released 2024
Scalable Kernel Machine Solver (EigenPro)
GPU solver that trains kernel machines fast and at scale.
-
Released 2024
Uncertainty Estimation with Recursive Feature Machines (RFM)
Uncertainty estimation with recursive feature machines.
-
Released 2024
Neural Parameter Symmetries
Code for studying how removing parameter symmetries changes neural network behavior.
-
Released 2022
Fast Training of Large Kernel Models (EigenPro 3)
Fast training of large kernel models.
Hyperdimensional & Efficient Computing
Brain-inspired hyperdimensional computing for science and the edge.
-
Released 2024
Hyperdimensional Genome Sketching (HyperGen)
Compact, efficient genome sketching with hyperdimensional vectors.
-
Released 2024
Hyperdimensional Neural Network Optimization for Resistive Memory (HDnn-RRAM-Opt)
Design optimization for hyperdimensional neural networks on RRAM processing-in-memory hardware.
-
Released 2024
Lifelong Hyperdimensional Learning at the Edge (LifeHD)
Lifelong on-device learning beyond the edge using hyperdimensional computing.
-
Released 2022
Hyperdimensional Mass Spectra Clustering (HyperSpec)
GPU-accelerated mass-spectra clustering with hyperdimensional computing for faster proteomics.
K-12 EDUCATIONAL ACTIVITIES
Introducing K-12 Students to Data Science and AI
In collaboration with middle and high school teachers and undergraduate interns, TILOS develops activities to introduce K-12 students to data science, programming, artificial intelligence, and optimization. Training is available to help teachers learn to run these activities and incorporate into curricula. Contact tilos@ucsd.edu to bring an activity to your classroom or event.
| AI Robotic Flower Data-driven Robotic Art Data Science Automatons Data Science Discovery Bootcamp |
Wearable AI Field trips to UC San Diego campus |
See the Lab 3.0 website for additional resources.
Community Partners
- Sweetwater Union High School District
- San Diego Union School District
- Scouting America (San Diego-Imperial Council)
- Heights Philadelphia
- George Washington High School
Data-driven Robotic Art
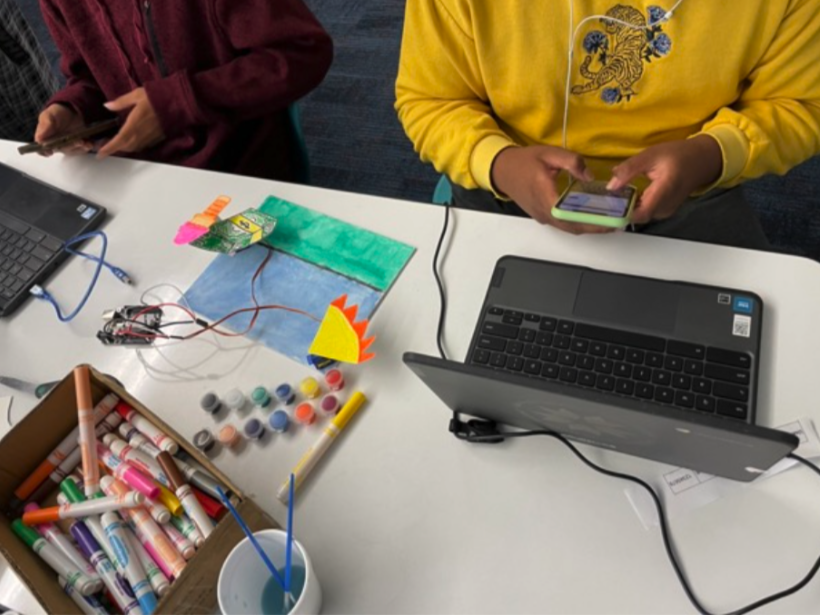
The Data-driven Robotic Art activity has students find a linear regression model for a dataset with two variables, then use the model to drive two servos that represent the variables in the model. See this PRESENTATION and complete this THIS FORM for more information.

AI Robotic Flower
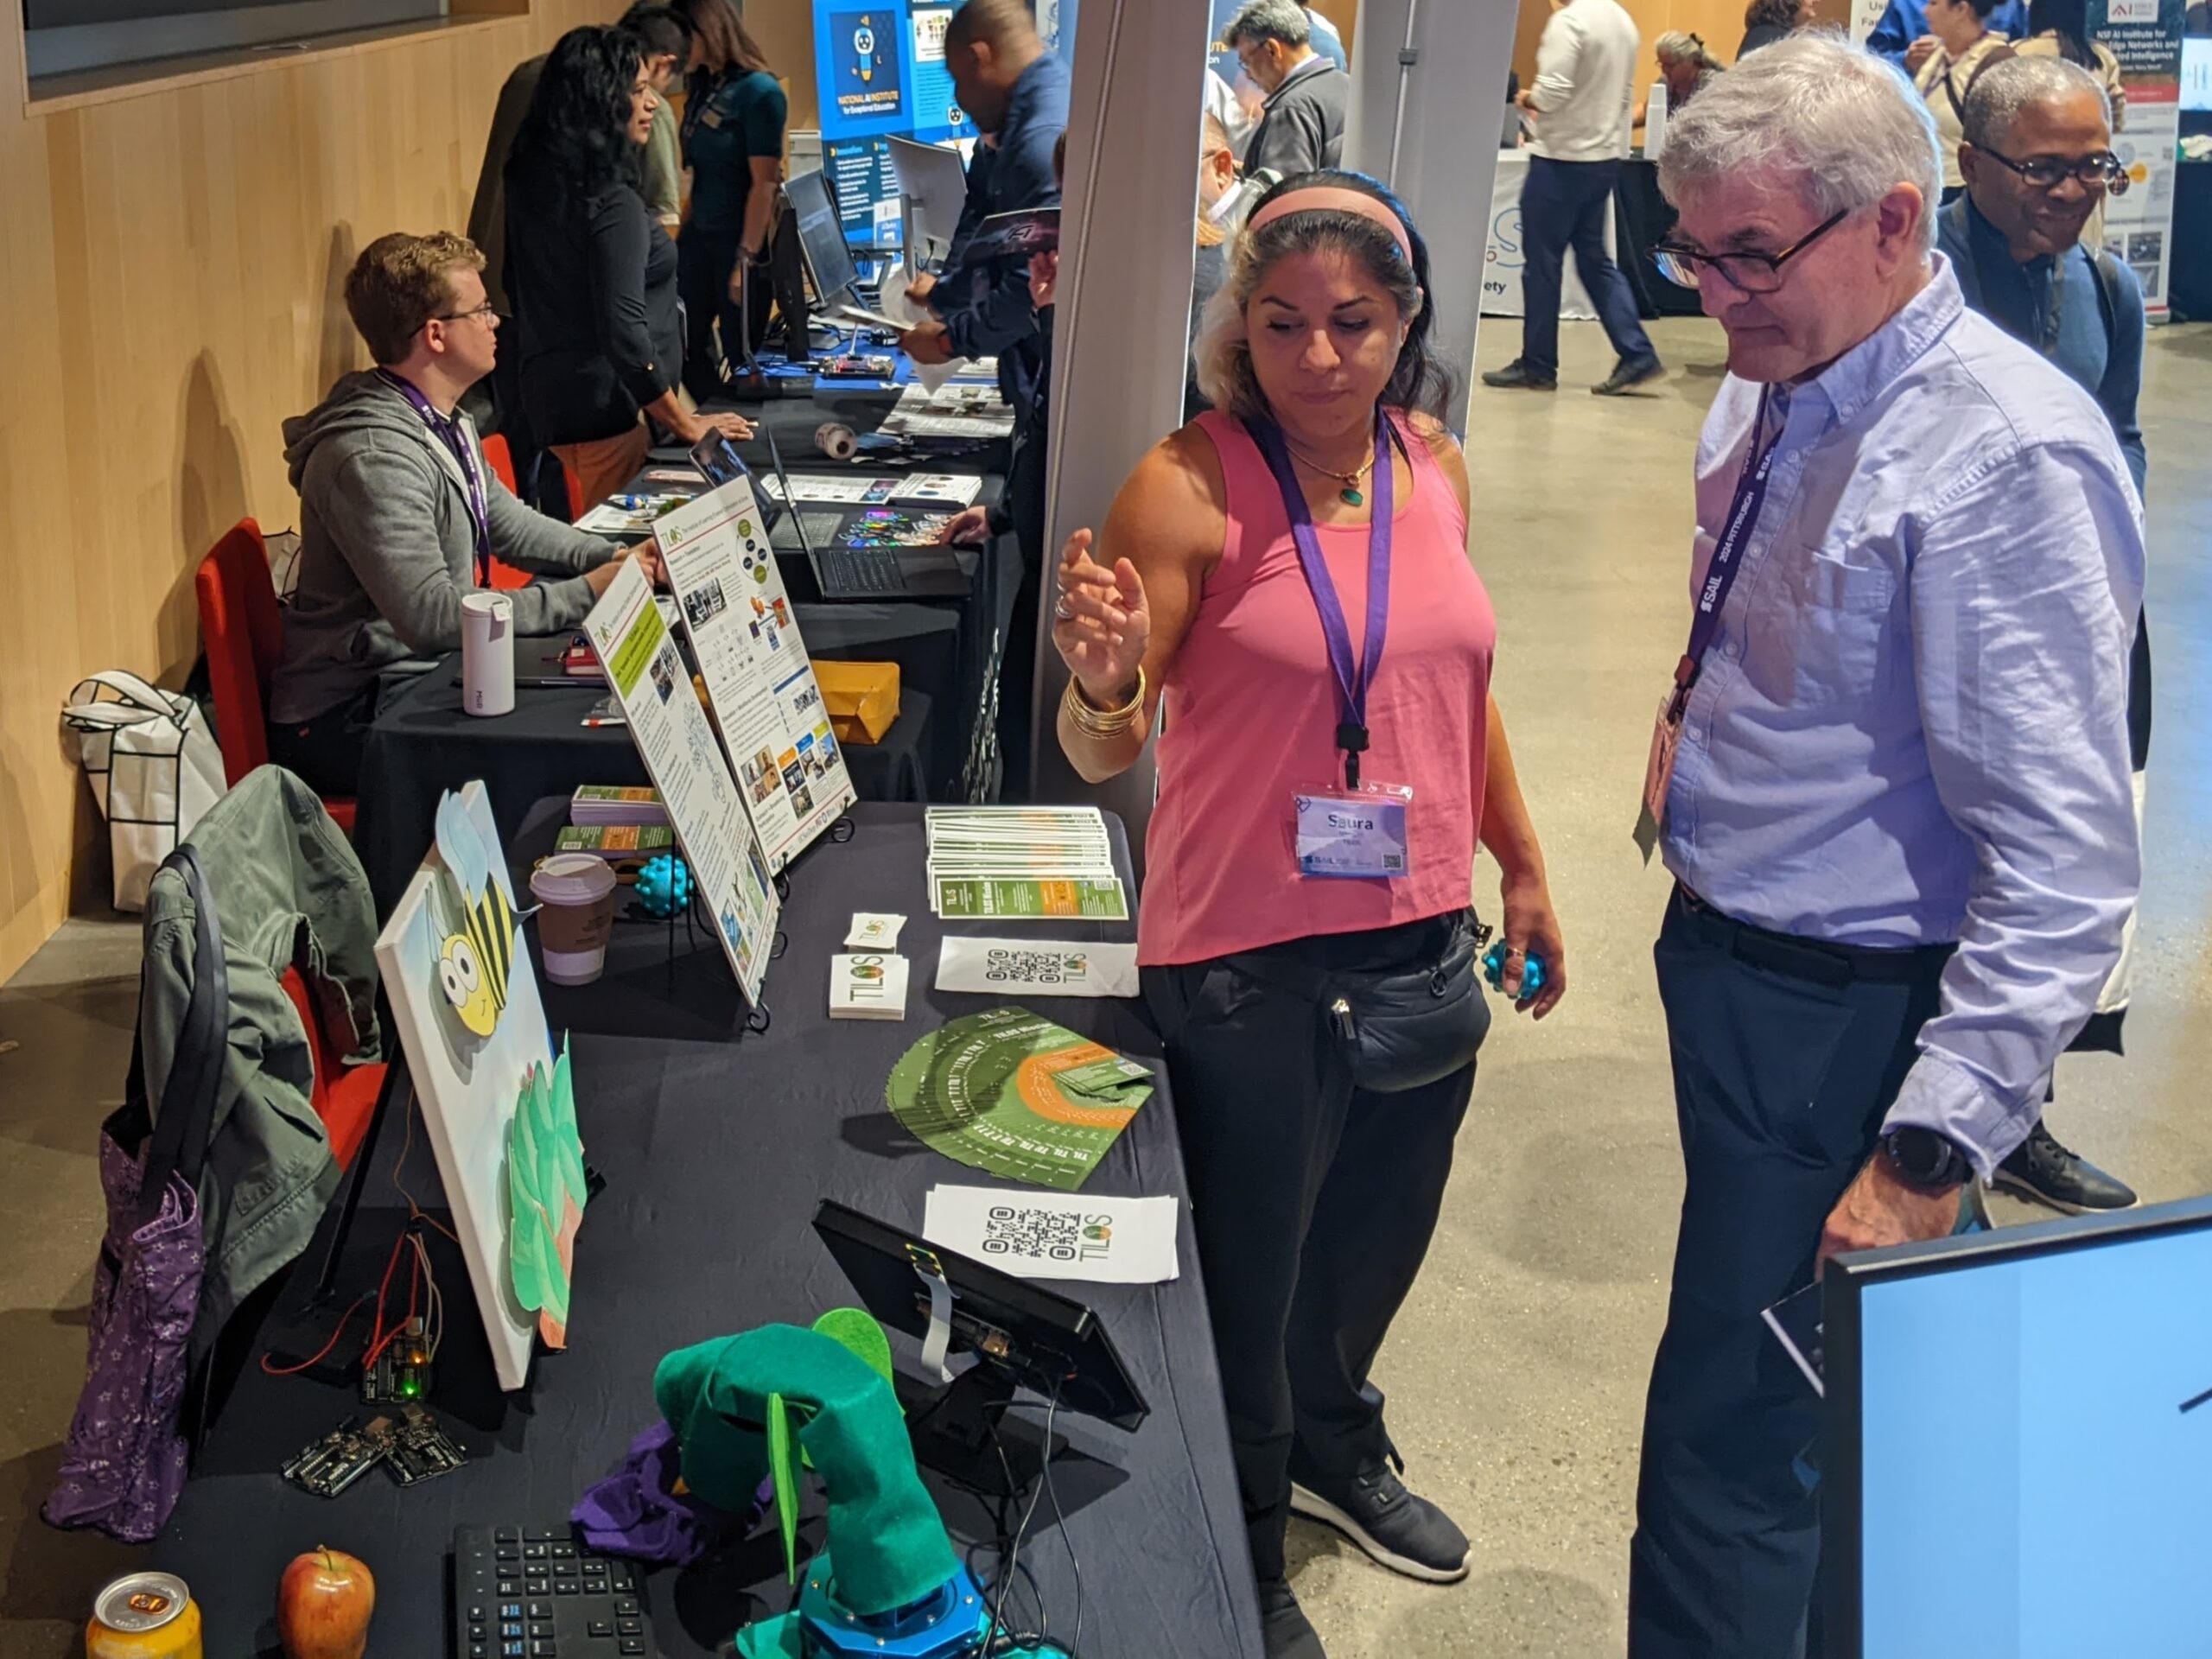
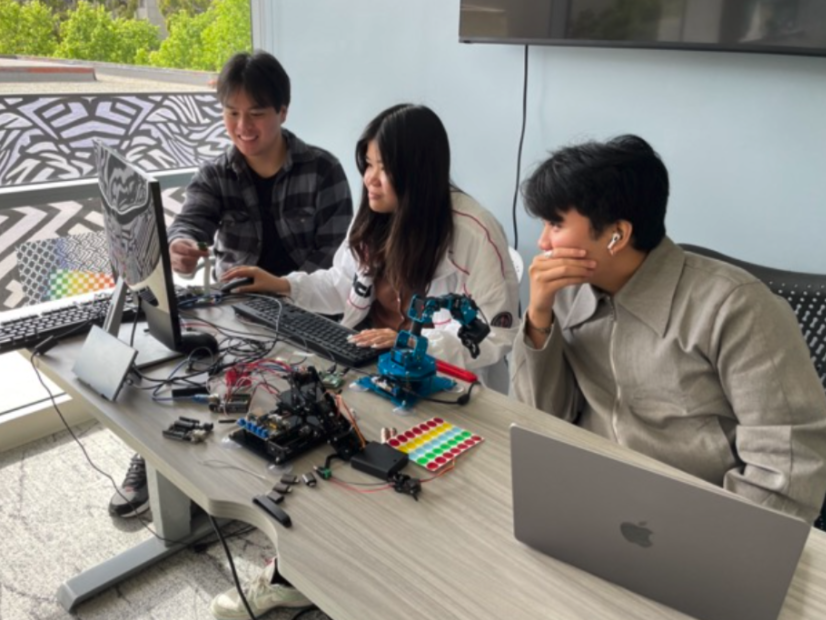
TILOS undergraduate students at UC San Diego have worked with Outreach Coordinator Saura Naderi to developed a prototype of an AI-driven art piece that will become our next outreach activity for high school students: a robotic flower that blooms when the user smiles at it and wilts when the user stops smiling.
Wearable AI
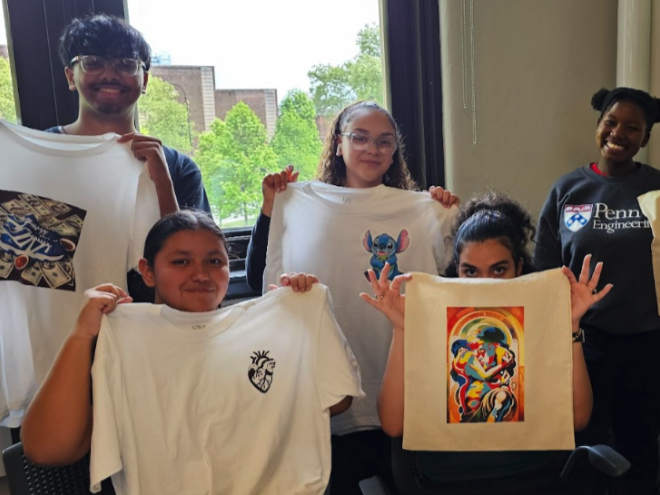
The Wearable AI activity has students learn about the capabilities of artificial intelligence and use OpenArtAI to design personalized graphics that the can be made into unique wearable pieces of art.
Data Science Automatons
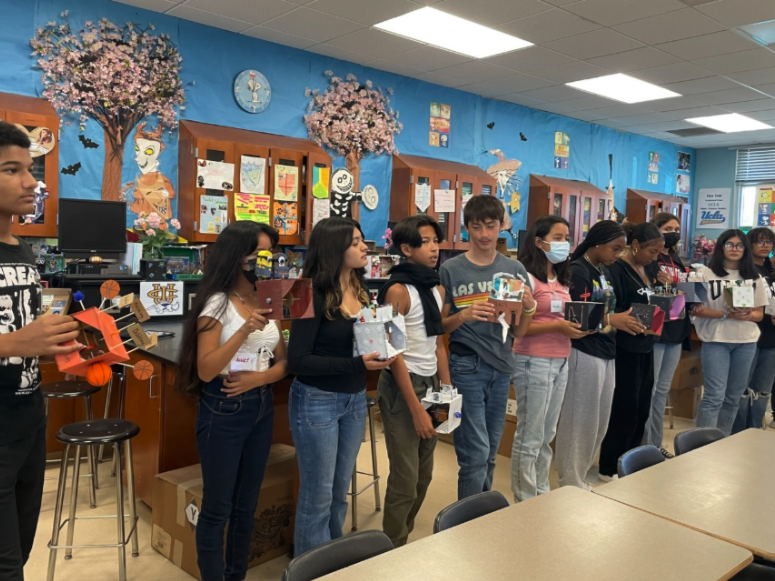
In the Data Science Automatons activity middle school students explore the frictional properties of different materials and employ data science concepts to analyze and interpret their findings.
Field Trips to UC San Diego

Tours for high school students of the UC San Diego campus provide opportunities for students to interact with the entire academic pipeline, from undergraduates and graduate students to postdoctoral scholars and faculty researchers. Please fill out THIS FORM if you are interested in a field trip.
Data Science Bootcamp
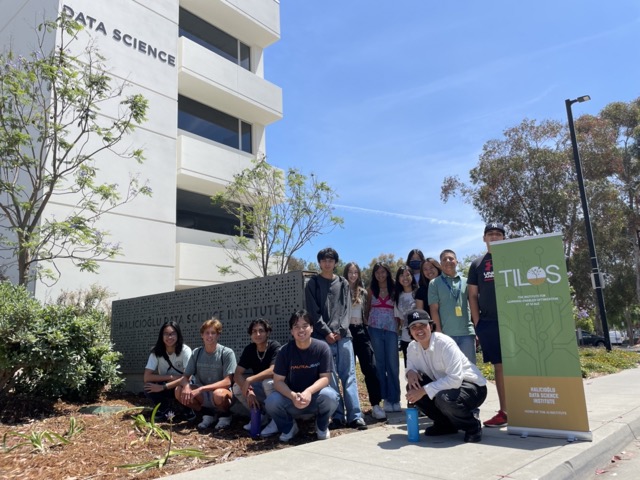
The Data Science Discovery Bootcamp is week-long summer day camp for local high school students, offered in partnership with a student organization at UC San Diego. Students are introduced to programming and data science with hands-on activities to make these topics more approachable for those with little or no coding experience, empowering them with the skills and confidence needed to pursue a college education and careers in data science.
"SCIENCE LIKE ME" VIDEO INTERVIEWS
Welcome to our video interview series, where we spotlight TILOS faculty and student researchers, as well as conversations with visiting researchers from academia and industry. In these candid conversations, you'll hear firsthand about their innovative research, they challenges they face, and the journeys that led them toward careers in AI and optimization research.
Why Topology Matters for Data Science and AI with Gunnar Carlsson
Topology offers a way to organize complex data by looking for shape, structure, and relationships. Yusu Wang, Ph.D., UC San Diego, and Gunnar E. Carlsson, Ph.D., Stanford University, discuss how ideas from algebraic topology move from pure mathematics into data science, machine learning, and AI. Carlsson explains why topological data analysis helps identify meaningful groups in large data sets, how examples and accessible tools can make abstract math useful, and why interpretability matters as AI systems grow more complex. The conversation connects collaboration across fields, customer-focused entrepreneurship, and the need to train mathematicians and AI researchers to help formulate real-world problems. Their exchange shows how mathematical thinking can make powerful technologies more understandable, usable, and accountable.
How Machine Learning Improves Algorithms with Ellen Vitercik
Hard optimization problems often look impossible through worst-case analysis, but real-world problems can contain structure that helps algorithms work faster. Ellen Vitercik, Ph.D., of Stanford University explains how machine learning can improve algorithm design for NP-hard optimization problems while preserving the formal guarantees that make solvers useful. She discusses beyond worst-case analysis, problem-specific heuristics, and the gap between tools that perform well in practice and methods that prove optimality. Vitercik also describes research on LLM reasoning using data structure tasks, where answers can be checked programmatically and failures reveal when models rely on pattern matching rather than true generalization. Her work helps clarify how AI may support stronger algorithms, more useful benchmarks, and more reliable reasoning systems.
Learning Beyond the Data: Adam Klivans on Distribution Shift and the Future of AI
Trustworthy machine learning requires models that still work when real-world data changes, and Adam Klivans, Ph.D., Director of the Institute for Foundations of Machine Learning (IFML), emphasizes learning under “distribution shift” as a major barrier to relying on models to predict disease across different patient populations. IFML focuses on foundational algorithms and mathematical techniques that push generative AI forward, including better methods for training and inference in deep learning and advances in diffusion approaches. Klivans highlights robustness and safety as core priorities, asking how to trust a model trained in one setting when it is applied in another. IFML connects these foundations to use-inspired domains such as imaging, protein engineering and biologics, and AI for mathematical discovery.
Big Data, Better Answers: Optimization at Scale with Courtney Paquette
Large-scale optimization and machine learning shape modern data science, and Courtney Paquette, Ph.D., McGill University, studies how to design and analyze algorithms for large-scale optimization problems motivated by applications and data science. Paquette draws on probability, complexity theory, and convex and non-smooth optimization, and examines scaling limits of stochastic algorithms. Speaking with Saura Naderi, UC San Diego, Paquette describes an unconventional path from finance to pure mathematics and explains how persistence and comfort with uncertainty support long-term research. She highlights the challenge of building missing foundations while advancing through graduate training, and she connects that experience to the realities of doing original work. Paquette also reflects on rapid progress in machine learning and frames AI systems as tools that can be used thoughtfully.
Artificial Intelligence and Security: A Conversation with Yaron Singer
Yaron Singer, Vice President of AI and Security at Cisco, co-founded a company specializing in artificial intelligence solutions, which was acquired by Cisco in 2024. They developed a firewall for artificial intelligence, a tool designed to protect AI from making critical mistakes. No matter how sophisticated AI is, errors can still happen, and these errors can have far-reaching consequences. The product is designed to detect and fix such mistakes. This technology was developed long before ChatGPT and its competitors burst onto the scene, making it the hottest industry in tech investment. Join Singer as he sits down with TILOS Foundations team member Mikhail (Misha) Belkin to discuss his work and the continued effort to make artificial intelligence secure.
Machine Learning, Fairness and AI: A Conversation with Adam Kalai
OpenAI researcher Adam Kalai sits down with TILOS Foundations team member Mikhail (Misha) Belkin to discuss his work in machine learning, algorithmic fairness, and artificial intelligence. Kalai has contributed research in areas like fairness in AI models, word embeddings, and human-AI collaboration. He has worked at Microsoft Research and has published influential papers on bias in machine learning models. His work has helped shape discussions on ethical AI and the development of more equitable AI systems.
Building Fast and Reliable Machine Learning Systems with Yian Ma
TILOS Foundations team member Yian Ma talks about his research using scalable inference methods for credible machine learning. This involves designing Bayesian inference methods to quantify uncertainty in the predictions of complex models; understanding computational and statistical guarantees of inference algorithms; and leveraging these scalable algorithms to learn from time series data and perform sequential decision making tasks.
Machine Learning and Mathematics with Tristan Brugère
Tristan Brugère, a Ph.D. student in the Halıcıoğlu Data Science Institute at UC San Diego, discusses his research at The Institute for Learning-enabled Optimization at Scale. Specifically, how he is working on optimal transport and neural networks on graph generative models with applications to chip design.
Using AI to Build Better Wireless Networks with Tara Javidi
TILOS Neworks team member Tara Javidi, an Electrical and Computer Engineering professor at UC San Diego's Jacobs School of Engineering, discusses her research in artificial intelligence and large-scale wireless networks.
The Future of Robotics with CJ Taylor
When not teaching at the University of Pennsylvania, CJ Taylor is part of the Robotics team working at The Institute for Learning-enabled Optimization at Scale. He talks with Saura Naderi about his upbringing, his early interest in data science, and his current position. He also talks about his involvement in projects that benefit the community.
UNIVERSITY & PROFESSIONAL

Intel AI for Workforce
The AI for Workforce program provides current and future workers with key skills in artificial intelligence. Community colleges use more than 500 hours of AI content and professional training for faculty to develop AI certificates, augment existing courses, and launch full AI associate degree programs.

SDSC Summer Institute
The Summer Institute is a week-long workshop run by the San Diego Supercomputer Center (SDSC) at UC San Diego. Aimed at researchers in academia and industry who have problems that cannot typically be solved using local computing resources, the workshop covers various topics in High Performance Computing and Data Science.

Data Science & Machine Learning Courses
TILOS supports the development of course modules by National University for their Certificate in AI and Machine Learning program, as well as Bachelor of Science and advanced degrees in Data Science.

The OpenROAD Project
Launched in 2018 as part of the Electronics Resurgence Initiative, OpenROAD's mission is to democratize integrated circuit design and boost both hardware and electronic design automation innovation at scale. The project is led by TILOS member Andrew Kahng at UC San Diego's VLSI CAD Laboratory.